
Physicl Raises $10 Million to Enhance Realism in Robot Training Simulations
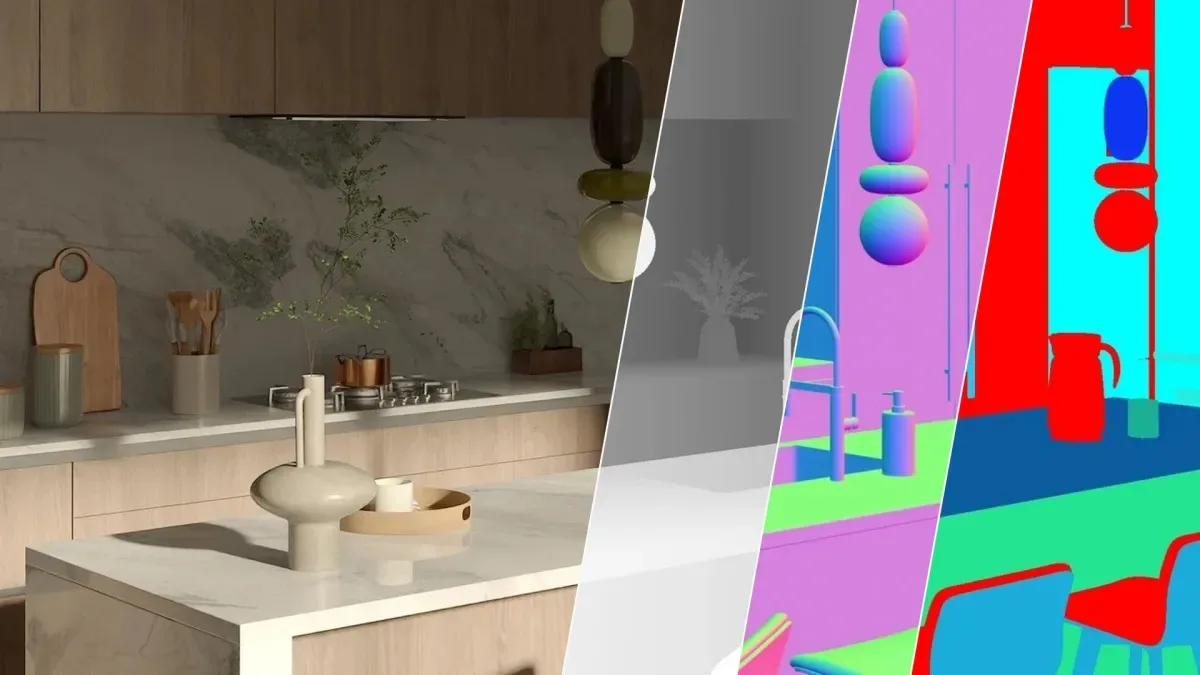
Image: TechCrunch · Source
Physicl has secured $10 million in seed funding to develop realistic 3D simulations aimed at improving robot training, addressing the challenges of bridging simulation to real-world performance.
Physicl, founded by Alex de Vigan, recently raised $10 million in seed funding from Inovia Capital to advance the realism of digital environments for training robots. The company builds on technology originally developed at de Vigan’s previous venture, nfinite, which specialized in creating high-fidelity 3D product renderings for e-commerce. While generative AI shifted nfinite’s focus, de Vigan recognized the potential of the core technology to tackle a critical problem in robotics: the sim-to-real gap.
Training physical AI models for robotic tasks—such as handling small, diverse objects—has been hindered by limited return from video data and the high cost of remote data collection. Digital simulations offer a promising alternative, but many struggle to reproduce accurate real-world physics, geometry, and materials. Physicl’s platform transforms unstructured and heterogeneous real-world information into detailed 3D representations that faithfully replicate physical properties, enabling more effective synthetic training data.
Physicl is entering a burgeoning field crowded with startups providing data and tools for foundational AI model builders and robot operators. Its differentiator is a focus on post-training challenges involving difficult edge cases. The startup’s product, Studio, offers 10,000 3D environments and 100,000 object assets, allowing users to craft specific scenes to generate synthetic data. For example, Studio can produce training scenarios where a robot struggles to identify a cup on a cluttered countertop or under shadows, helping improve robotic perception in complex settings.
Early adopters, such as SpAItial—a world model developer—have used Physicl’s synthetic data to enhance 3D simulation fidelity. SpAItial’s CEO, Matthias Niessner, noted that Physicl’s data enables training necessary for converting 2D images into accurate 3D models in their Echo-3 product. Niessner also highlighted the innovation in Physicl’s approach: the ability to auto-generate tailored synthetic data dynamically during training, reducing long manual data curation cycles.
Founder de Vigan envisions Physicl as more than a static data provider. His platform can ingest vast datasets—trillions of images or millions of hours of LIDAR scans—and process them into high-quality 3D worlds that support billions of training permutations. This agentic workflow facilitates continuous synthetic data generation, empowering roboticists to refine models with on-demand scenario creation.
Physicl’s funding and product launch indicate growing momentum in robotic simulation technologies, offering new avenues to overcome persistent barriers in training robots for real-world tasks. By bridging physical and digital worlds through high-fidelity 3D environments, Physicl aims to accelerate the development and deployment of more capable autonomous systems.
Sources and original reporting
Read the original source ↗
Comments (0)
No comments yet. Start the discussion.
Write a comment
Comments are published after moderation. Your name and comment will be visible publicly. Account